All topics

Robotics & Physical Interfaces

Robotics combines mechanical assembly, sensing, control, and software. Those jobs have different failure modes. This collection separates documented builds from research demonstrations, so a rover manual, an experimental haptic dial, and a new robot-learning result do not look like interchangeable weekend projects.

Follow this topic

Where to start

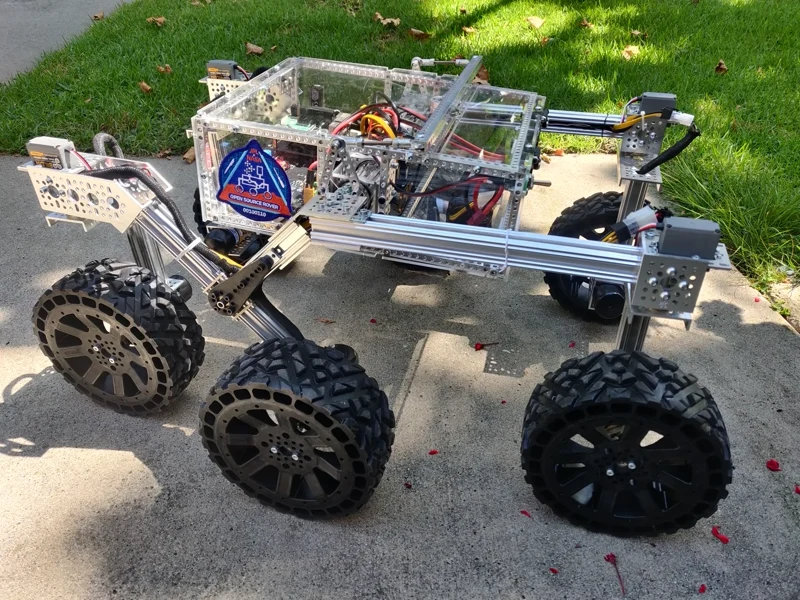
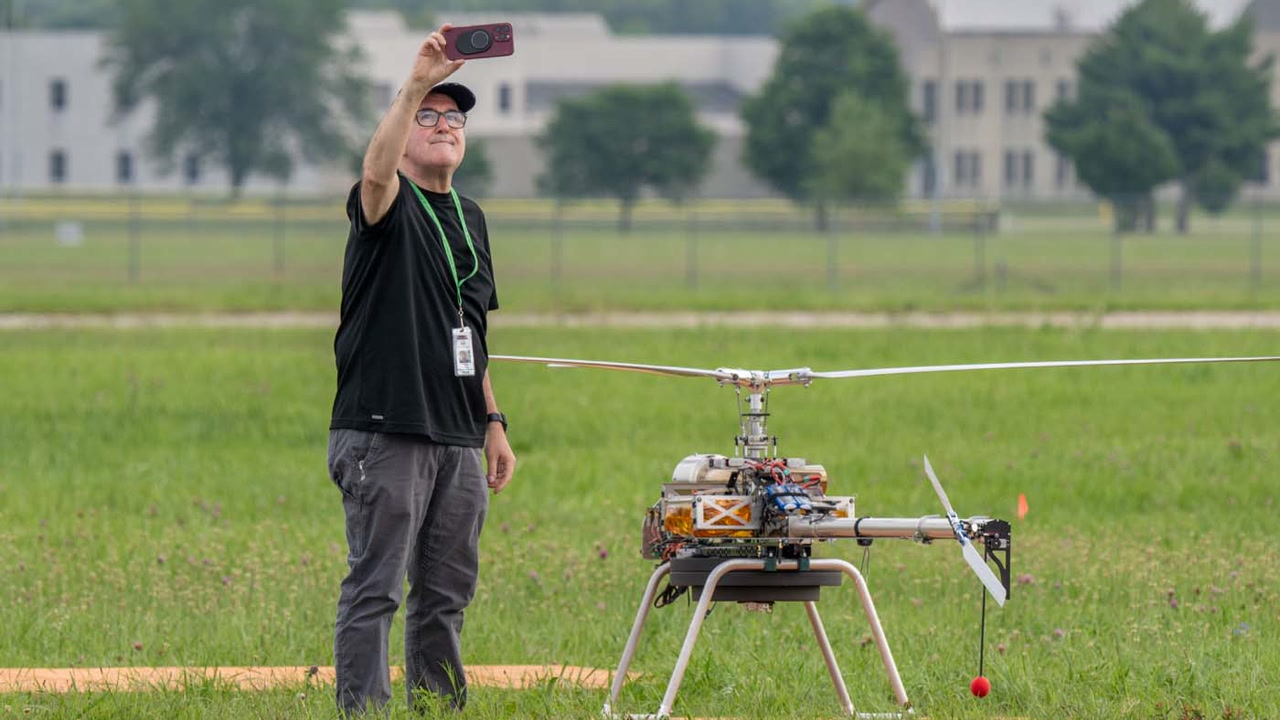
Build JPL's Six-Wheel Open Source Rover

A complete multi-chapter mechanical and electrical build.

Photo credit

images/osr-side-outside.jpg

JPL / California Institute of Technology and Open Source Rover contributors · Apache-2.0

Resized without cropping and converted to WebP for the project card.

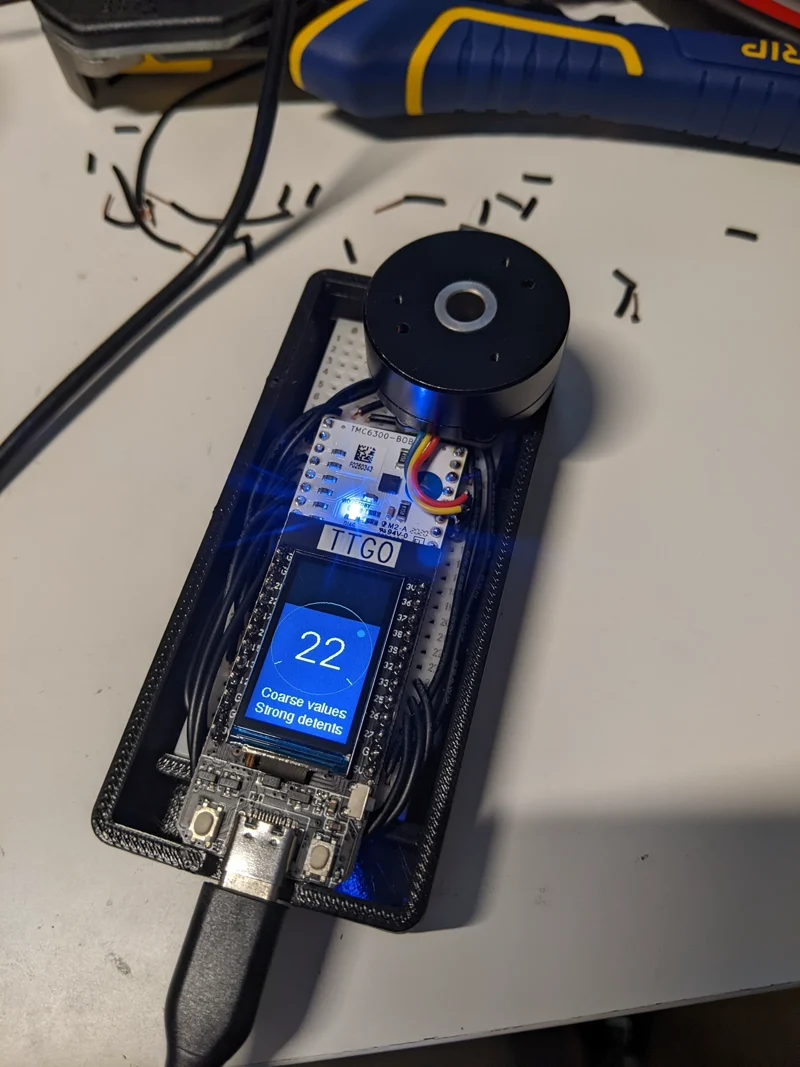
SmartKnob: Build a Dial That Changes How It Feels

An advanced interface prototype with programmable feel.

Photo credit

doc/img/PXL_20220212_013249074.jpg

Scott Bezek · Apache-2.0

Resized without cropping and converted to WebP for the project card.

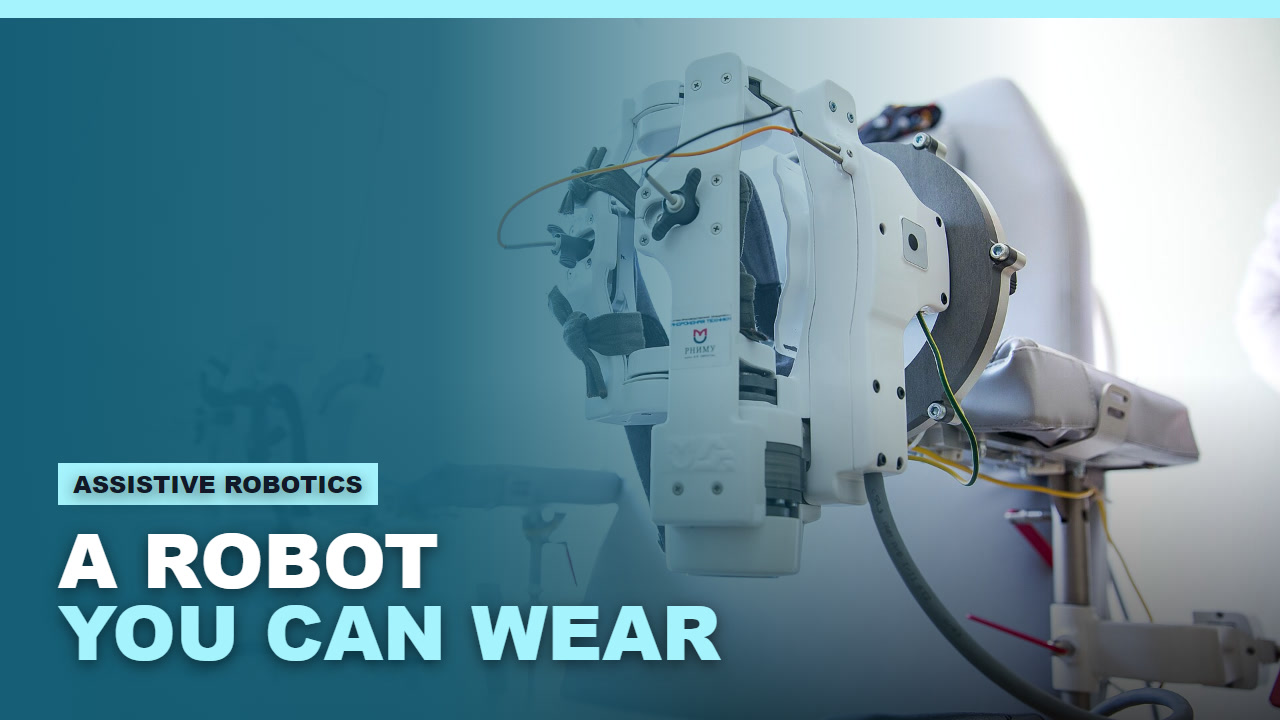
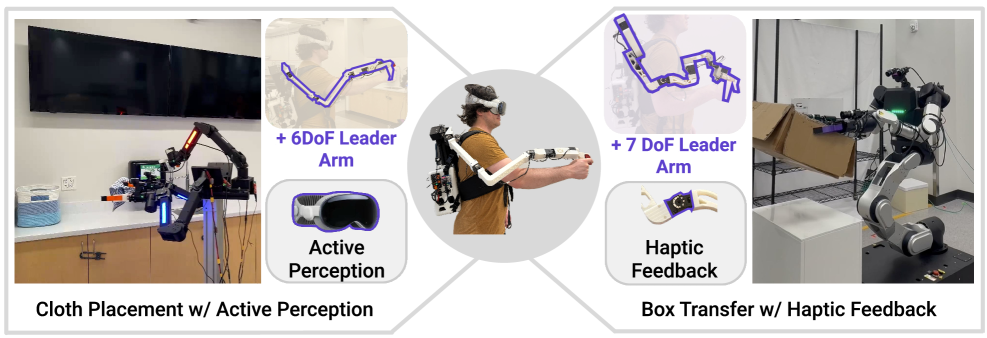
ModPack Turns Robot Teleoperation Into a Wearable, Modular System

Research context for wearable robot control.

Choose your mechanical commitment

JPL's rover is a substantial build with separate body, wheel, rocker-bogie, wiring, and PCB chapters. SmartKnob is smaller, but it is still an advanced prototype involving a motor, electronics, firmware, and a mechanical assembly. Small size does not necessarily mean simple construction.

Read the limits alongside the demonstration

Our teleoperation, planning, and soft-robotics coverage explains what was demonstrated rather than promising a ready-to-use robot. Start with the original source and the specific task. A successful grasp, a wearable controller, or a simulation result does not establish reliable autonomous behavior in every environment.

11 stories and builds

SmartKnob: Build a Dial That Changes How It Feels
Photo credit

doc/img/PXL_20220212_013249074.jpg

Scott Bezek · Apache-2.0

Resized without cropping and converted to WebP for the project card.

Prototype referenceAdvanced

SmartKnob: Build a Dial That Changes How It Feels

Scott Bezek's complete SmartKnob README: brushless-motor haptics, configurable stops and clicks, original prototype photograph and exploded animation, PCB notes, and build limitations.

Scott Bezek

Added Oct 3, 2026
Build JPL's Six-Wheel Open Source Rover
Photo credit

images/osr-side-outside.jpg

JPL / California Institute of Technology and Open Source Rover contributors · Apache-2.0

Resized without cropping and converted to WebP for the project card.

Build guideAdvanced

Build JPL's Six-Wheel Open Source Rover

The complete reviewed JPL rover hardware manual: parts lists, wiring, PCB assembly, mechanical chapters, original build photographs and diagrams, optional mast, and downloadable schematics.

JPL / California Institute of Technology and Open Source Rover contributors

Added Oct 3, 2026